Impulse Function, Signal Classes and Fourier Properties
Properties of the Impulse Function
Answer
The impulse function, often denoted as the Dirac delta function δ(t), has several important properties that make it a useful tool in mathematics, physics, and engineering, particularly in signal processing and systems analysis. Here are the key properties:
Sifting Property
The most important property of the Dirac delta function is its sifting property. For any continuous function f(t):
∫−∞∞ f(t) δ(t − t0) dt = f(t0)
This means the integral of a function multiplied by the delta function picks out the value of the function at t0.
Normalization
The integral of the delta function over the entire real line equals one:
∫−∞∞ δ(t) dt = 1
Scaling Property
If a is a nonzero constant, then the delta function scales as:
δ(a t) = (1 / |a|) δ(t)
Shifting Property
The delta function can be shifted in time: δ(t − t0) represents an impulse occurring at time t0.
Derivative of the Delta Function
The derivative of the delta function, δʼ(t), satisfies:
∫−∞∞ f(t) δʼ(t − t0) dt = −fʼ(t0)
Convolution with the Delta Function
Convolving a function f(t) with the delta function yields the function itself:
f(t) * δ(t) = f(t)
Classification of Signals
Answer
Signals can be classified based on various criteria including their time domain behavior, amplitude, periodicity, symmetry, energy/power, determinism, and application. Common classifications include:
1. Based on Time Characteristics
- Continuous-time signals: Defined for all time (e.g., analog sine waves).
- Discrete-time signals: Defined only at discrete time instants (e.g., sampled signals).
2. Based on Amplitude Characteristics
- Analog signals: Can take any value in a range (continuous amplitude).
- Digital signals: Take a finite set of values (e.g., binary values 0 and 1).
3. Based on Periodicity
- Periodic signals: Repeat at regular intervals (e.g., sine waves).
- Aperiodic signals: Do not repeat (e.g., noise, transient signals).
4. Based on Symmetry
- Even signals: Symmetric about t = 0 (e.g., cosine).
- Odd signals: Anti-symmetric about t = 0 (e.g., sine).
5. Based on Energy and Power
- Energy signals: Finite energy E = ∫−∞∞ |x(t)|² dt (0 < E < ∞). Examples: pulses, decaying exponentials.
- Power signals: Finite average power but infinite energy. Power P = limT→∞ (1 / 2T) ∫−TT |x(t)|² dt (0 < P < ∞). Examples: sinusoids.
6. Based on Determinism
- Deterministic signals: Exactly described by a mathematical expression (e.g., sinusoids).
- Random signals: Characterized statistically (e.g., noise).
7. Based on Applications
- Communication signals: For information transmission (audio, video).
- Control signals: Used to regulate systems.
- Sensor signals: Generated by sensors (temperature, pressure).
Periodic and Aperiodic Signals
Answer
Periodic and aperiodic signals are key in signal processing and communications:
Periodic Signal
A signal x(t) is periodic if there exists a fundamental period T such that:
x(t) = x(t + T) for all t.
Examples: sine wave, square wave. Characteristics: definite period T, repetitive, representable by Fourier Series.
Aperiodic Signal
An aperiodic signal does not repeat at fixed intervals and has no fundamental period. Examples: exponentially decaying signals, speech, noise. Typically analyzed with the Fourier Transform rather than Fourier Series.
Key difference: Periodic signals exhibit cyclic behavior; aperiodic do not.
Complex Exponential
Answer
A complex exponential has the form:
x(t) = A e^{j(ω t + φ)}
where A is amplitude, j is the imaginary unit, ω is angular frequency, and φ is phase.
Key Properties
- Euler's formula: e^{jθ} = cos(θ) + j sin(θ).
- Oscillatory behavior: Represents sinusoidal oscillations.
- Real and imaginary parts: A e^{jωt} = A cos(ωt) + j A sin(ωt).
- Fourier analysis: Complex exponentials form the basis for Fourier Series and Transforms.
- Multiplicative property: e^{j a} ⋅ e^{j b} = e^{j(a + b)}.
- Period: Repeats every 2π / ω.
Energy and Power Signals
Answer
Signals are classified by their energy and power:
Energy Signal
Signal x(t) is an energy signal if its energy E = ∫−∞∞ |x(t)|² dt is finite (0 < E < ∞). Typical examples: pulses, decaying exponentials.
Power Signal
Signal x(t) is a power signal if it has finite nonzero average power but infinite energy. Power is computed as:
P = limT→∞ (1 / 2T) ∫−TT |x(t)|² dt
Examples: sinusoidal signals, ongoing random processes.
Key differences
Energy: finite vs infinite. Power: zero vs finite. Energy signals are often transients; power signals model persistent oscillatory behavior.
Bounded and Unbounded Signals
Answer
Signals are bounded if their amplitude remains within a finite value M for all time:
|x(t)| ≤ M for all t (M finite).
Unbounded signals grow without bound as t → ∞ (e.g., exponential growth, ramp functions). Bounded signals are preferred in control and engineering to ensure stability.
Discrete-Time Signal and Its Representation
Answer
Discrete-time signals are defined only at discrete instants and are denoted x[n], where n is an integer. Representation methods include:
- Graphical representation
- Functional representation
- Tabular representation
- Sequence representation
Graphical Representation of Discrete-Time Signals
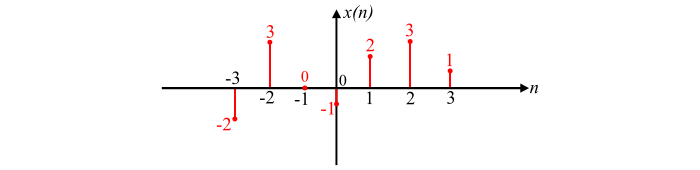
Consider the discrete-time signal x[n] with values:
x[−3] = −2, x[−2] = 3, x[−1] = 0, x[0] = −1, x[1] = 2, x[2] = 3, x[3] = 1
This discrete-time signal can be represented graphically (see figure below):
Functional Representation of Discrete-Time Signal
Writing magnitude against n gives:
x[n] = { −2 for n = −3; 3 for n = −2; 0 for n = −1; −1 for n = 0; 2 for n = 1; 3 for n = 2; 1 for n = 3 }
Tabular Representation of Discrete-Time Signal
Sample index n and the corresponding x[n] value in table form:
| n | −3 | −2 | −1 | 0 | 1 | 2 | 3 |
| x[n] | −2 | 3 | 0 | −1 | 2 | 3 | 1 |
Sequence Representation of Discrete-Time Signal
The sequence representation lists the samples; the arrow denotes n = 0:
x[n] = { −2, 3, 0, −1, 2, 3, 1 ↑ }
When no arrow is shown, the first term corresponds to n = 0 by convention.
Sum and Products of Discrete-Time Sequences
Sum: The sum of two sequences is element-wise: if c[n] = a[n] + b[n], then c[n] = a[n] + b[n].
Product: The product of two sequences is element-wise: c[n] = a[n] · b[n].
Scalar multiplication: The product of a sequence and a constant k yields c[n] = k · a[n].
Tabular Representation of Discrete-Time Signal: (duplicate content retained as required)
| n | −3 | −2 | −1 | 0 | 1 | 2 | 3 |
| x[n] | −2 | 3 | 0 | −1 | 2 | 3 | 1 |
Operations on Discrete-Time Signals (DTS)
Answer
Operations on discrete-time signals include mathematical manipulations useful for analysis and processing.
1. Basic Operations
- Addition: y[n] = x1[n] + x2[n]
- Subtraction: y[n] = x1[n] − x2[n]
- Multiplication (element-wise): y[n] = x1[n] · x2[n]
2. Time Shifting
- Advance (right shift): y[n] = x[n − k]
- Delay (left shift): y[n] = x[n + k]
3. Scaling
- Amplitude scaling: y[n] = A x[n]
- Time scaling: y[n] = x[k n]
4. Folding (Time Reversal)
Reflect the signal across n = 0: y[n] = x[−n]
5. Convolution
Fundamental operation for linear systems:
y[n] = Σk=−∞∞ x1[k] · x2[n − k]
Used for system analysis, filtering, and digital communications.
6. Differencing (First Difference)
Numerical differentiation: y[n] = x[n] − x[n − 1]
7. Accumulation (Summation)
Discrete integration over time: y[n] = Σk=−∞n x[k]
Relationship Between Impulse and Step Function
Answer
The impulse (delta) and step functions are closely related via differentiation and integration.
1. Impulse Function (Dirac Delta)
- The impulse δ(t) is zero everywhere except at t = 0 and integrates to one: ∫−∞∞ δ(t) dt = 1.
- It models a sudden instantaneous change.
2. Step Function (Unit Step)
The unit step u(t) is defined as:
u(t) = { 1, t ≥ 0; 0, t < 0 }
It represents a signal that switches ON at t = 0.
3. Relationship
Differentiation
The derivative of the unit step yields the delta:
d/dt u(t) = δ(t)
Integration
The integral of the delta yields the unit step:
∫−∞t δ(τ) dτ = u(t)
4. Physical Interpretation
- The impulse models an instantaneous force or change.
- The step models a cumulative effect (switching from OFF to ON).
Properties of the Delta Function (Summary)
Answer
Key properties already noted include:
1. Sifting Property
∫−∞∞ f(t) δ(t − a) dt = f(a)
2. Integral Property
∫−∞∞ δ(t) dt = 1
3. Time Scaling
δ(a t) = (1 / |a|) δ(t)
4. Time Shifting
δ(t − a) represents an impulse at t = a.
5. Differentiation
d/dt u(t) = δ(t)
6. Fourier Transform
The Fourier transform of δ(t) is a constant in frequency (contains all frequencies equally): F{δ(t)} = 1
Static and Dynamic Systems
Answer
Static System
A static (memoryless) system's output depends only on the current input. Characteristics: no memory, instantaneous response. Examples: algebraic relations like V = IR.
Dynamic System
A dynamic system has memory; the output depends on current and past inputs and evolves over time. Often described by differential or difference equations. Examples: circuits with capacitors/inductors, mechanical systems with inertia.
Key Differences
| Property | Static System | Dynamic System |
|---|---|---|
| Memory | No memory | Has memory |
| Response | Instantaneous | Evolves over time |
| Equation Type | Algebraic | Differential or difference |
Causal, Non-Causal and Anti-Causal Systems
Answer
Classification by causality:
- Causal system: Output at time t depends only on present and past inputs. (Real-time physical systems are typically causal.)
- Non-causal system: Output depends on future inputs as well as past/present. Used in offline processing or theoretical analyses.
- Anti-causal system: Output depends only on future inputs (not physically real-time implementable).
Time-Invariant and Time-Variant Systems
Time-invariant systems preserve the shape of responses under time shifts. Time-variant systems have properties that change with time (e.g., varying gain).
| Feature | Time-Invariant | Time-Variant |
|---|---|---|
| Response Shift | Maintains shift | Changes with time |
| Equation Stability | Remains same | Varies over time |
Linear and Nonlinear Systems
Answer
Linear systems obey superposition and scaling. Nonlinear systems do not.
Linear System
- Superposition: x1 → y1 and x2 → y2 implies x1 + x2 → y1 + y2.
- Scaling: k x(t) → k y(t).
- Characteristics: predictable, analyzable by linear methods.
Nonlinear System
- Does not satisfy superposition or scaling. Can exhibit complex behaviors such as chaos and bifurcations.
- Often requires numerical methods for analysis.
Key Differences
| Property | Linear System | Nonlinear System |
|---|---|---|
| Superposition | Holds | Does not hold |
| Scaling | Holds | Does not hold |
| Complexity | Simple | Complex, possibly chaotic |
Stable and Unstable Systems
Answer
System stability describes whether bounded inputs produce bounded outputs (BIBO stability).
Stable System
If |x(t)| is bounded, then |y(t)| is bounded. Stable systems' responses settle and remain predictable.
Unstable System
A bounded input can produce an unbounded output (|y(t)| → ∞). This requires stabilization techniques.
Marginally Stable
System that neither grows unbounded nor decays; it oscillates indefinitely (e.g., ideal undamped LC circuit).
Key Differences
| Property | Stable | Unstable | Marginally Stable |
|---|---|---|---|
| Output Growth | Bounded | Unbounded | Neither decays nor grows |
Invertible and Non-Invertible Systems
Answer
An invertible system allows recovery of the input uniquely from the output; a non-invertible system loses information.
Invertible System
There exists an inverse system H−1 such that H−1[y(t)] = x(t). Example: multiplication by a nonzero constant.
Non-Invertible System
No unique inverse exists; information loss occurs (e.g., squaring function y = x²).
Continuous-Time Fourier Series (CTFS)
Answer
CTFS decomposes a periodic signal into complex exponentials:
x(t) = Σn=−∞∞ Cn e^{j n ω0 t}
where ω0 = 2π / T and the Fourier coefficients are:
Cn = (1 / T) ∫0T x(t) e^{−j n ω0 t} dt
Alternate Sinusoidal Form
x(t) = A0 + Σn=1∞ [An cos(n ω0 t) + Bn sin(n ω0 t)]
Properties and Applications
- Periodicity, orthogonality, convergence conditions.
- Used in signal analysis, audio and image processing, circuit frequency response.
Properties of Fourier Series
Answer
- Linearity: Fourier coefficients add for sum of signals.
- Periodicity: Applies only to periodic signals.
- Symmetry: Even signals contain only cosines; odd signals only sines.
- Time shifting: Shifts introduce phase factors to coefficients.
- Frequency shifting, convolution, differentiation/integration, Parseval's theorem, Gibbs phenomenon.
Properties of Fourier Transform
Answer
The Fourier Transform converts time-domain signals into frequency-domain representations. Key properties include:
- Linearity
- Time shifting: x(t − t0) ⇒ X(f) e^{−j 2π f t0}
- Frequency shifting
- Convolution: Time-domain convolution ⇒ frequency-domain multiplication.
- Differentiation in time ⇔ multiplication by j 2π f in frequency.
- Parseval's theorem: energy equality between time and frequency domains.
- Time scaling and duality.
- Inverse Fourier Transform: x(t) = ∫−∞∞ X(f) e^{j 2π f t} df
Properties of the DTFT
Answer
The Discrete-Time Fourier Transform (DTFT) analyzes discrete signals in frequency domain. Key properties:
- Linearity
- Time shifting: x[n − n0] ⇒ e^{−j ω n0} X(ω)
- Frequency shifting
- Convolution: Time-domain convolution ⇒ frequency-domain multiplication.
- Parseval's theorem: Σn |x[n]|² = (1 / 2π) ∫−ππ |X(ω)|² dω
- Periodicity: DTFT is 2π-periodic: X(ω) = X(ω + 2π).
- Duality: symmetry between time and frequency representations.
Key Causality Differences (Summary Table)
| Type | Depends on Past | Depends on Present | Depends on Future |
|---|---|---|---|
| Causal | Yes | Yes | No |
| Non-Causal | Yes | Yes | Yes |
| Anti-Causal | No | No | Yes |
Causality is a crucial concept in control systems, signal processing, and physics.